How developers learn robotics
4/10 open
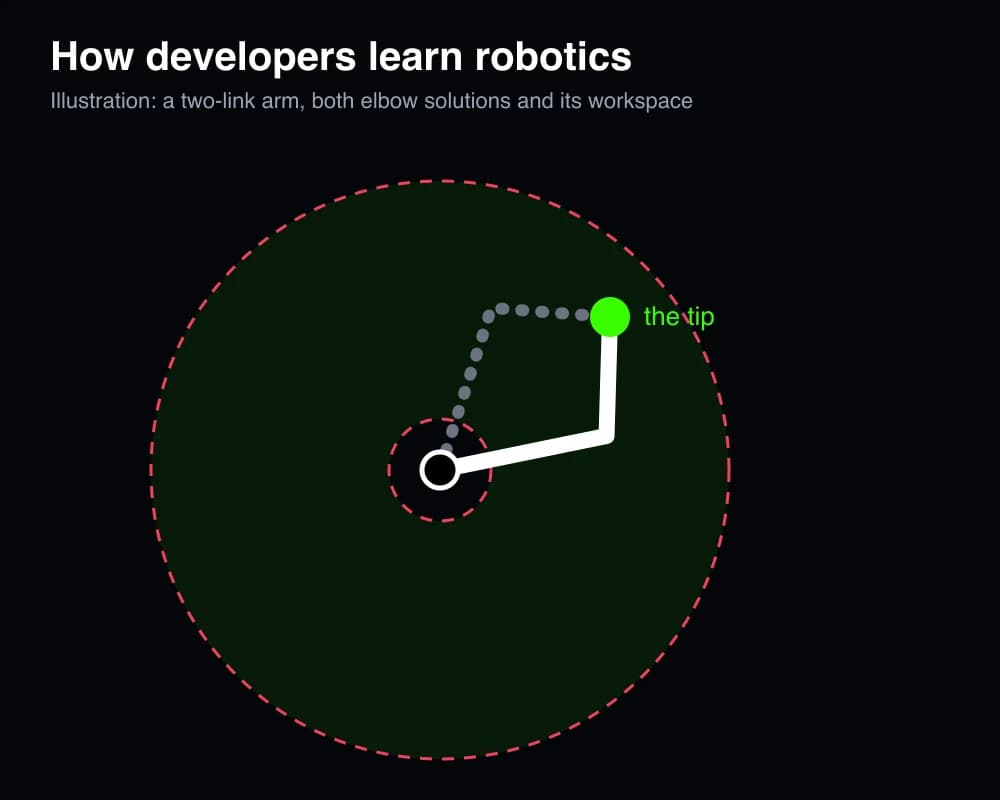
Two on-ramps, one shared core and a real humanoid to finish: drag a frame tree, a two-link arm and a PID.
- Frames and transforms
- Kinematics of a two-link arm
- Tuning a PID
- ROS 2: the graph · coming
- Simulation · coming
- Perception · coming
- Localisation and navigation · coming
- Manipulation and planning · coming
- Learning-based control · coming
- Asimov 1, end to end